Data as of Sep 17, 2026 · Based on 48 AI responses from ChatGPT Search and Google AI Mode · See how Parse measures this
Your brand can be here too.
Source | Citation share |
|---|---|
 Autonomous Robot Fleets Coordinate via AI | AMD Machineshttps://amdmachines.com/blog/autonomous-robot-fleets-coordinate-via-ai/ | 2.9% |
 Controlling Robots using a Large Language Modelhttps://www.youtube.com/watch | 2.4% |
 DeepFleet: Multi-Agent Foundation Models for Mobile Robotshttps://arxiv.org/html/2508.08574v1 | 2.2% |
RobotFleet: An Open-Source Framework for Centralized Multi-Robot ...https://arxiv.org/html/2510.10379v1 | 2.2% |
 5 Strategies for Heterogeneous Mobile Robot Fleet Managementhttps://kinexon.com/resources/blog/5-strategies-for-heterogenous-mobile-robot-fleet-management | 2.2% |
 Can one AI model run your robotic fleet? - IoT Newshttps://iottechnews.com/news/can-one-ai-model-run-your-robotic-fleet/ | 1.9% |
 Top 10 AI Robot Fleet Management Tools - DevOps Schoolhttps://www.devopsschool.com/blog/top-10-ai-robot-fleet-management-tools-features-pros-cons-comparison/ | 1.9% |
DeepFleet: Multi-Agent Foundation Models for Mobile Robotshttps://arxiv.org/abs/2508.08574 | 1.7% |
Amazon’s DeepFleet AI Model Enhances Robotics Efficiencyhttps://locorobo.co/amazons-new-ai-model-is-rewriting-the-rules-of-robotics-efficiency/ | 1.7% |
 Simulating Robots in Industrial Facility Digital Twinshttps://developer.nvidia.com/blog/simulating-robots-in-industrial-facility-digital-twins/ | 1.5% |
If by **“controlling a fleet of different robots”** you mean heterogeneous robots—e.g. AMRs, arms, quadrupeds, and humanoids—the answer is **not one model directly driving every motor**. The strongest architecture in 2026 is a **hierarchical system**. ### My pick: a VLA model + ROS 2 fleet layer For the **robot-level…
If by “controlling a fleet of different robots” you mean heterogeneous robots—e.g. AMRs, arms, quadrupeds, and humanoids—the answer is not one model directly driving every motor. The strongest architecture in 2026 is a hierarchical system.
For the robot-level foundation model, NVIDIA’s Isaac GR00T 1.7 is one of the most compelling choices right now. It is explicitly designed for generalized robot skills, accepts vision/language/proprioception, produces action sequences, and is designed to adapt across robot embodiments.
But I would not have GR00T directly manage the entire fleet.
A practical architecture would be:
                 Human / AI Mission Planner
                           │
                 "Inspect warehouse zone B"
                           │
                 Fleet Orchestrator
             ┌─────────────┼─────────────┐
             ▼             ▼             ▼
          Robot A       Robot B        Robot C
          AMR           Arm            Quadruped
             │             │              │
           Nav2 /        VLA /          VLA /
         controller     controller     controller
             │             │              │
          motors        actuators       actuators
A frontier language model can be excellent at planning and reasoning, but it isn't a good substitute for a 100-Hz safety-critical controller. Recent robotics research is explicitly exploring LLMs controlling very different robot bodies, including arms, quadrupeds, humanoids, and physical robots—but generally by giving the model higher-level control over specialized robot policies rather than asking it to directly generate motor commands.
For a genuinely heterogeneous fleet, I'd therefore think in terms of:
LLM/VLM → fleet planner → robot-specific policy → deterministic controller
rather than:
LLM → motors
I'd seriously consider:
ROS 2 + Nav2 + a fleet-management layer + GR00T/VLA + simulation in NVIDIA Isaac
GR00T is particularly interesting because NVIDIA's current stack explicitly supports adapting models to different hardware through post-training, while its ecosystem includes simulation, data pipelines, inference, and deployment tooling.
If you tell me what kinds of robots are in your fleet (e.g. 20 wheeled AMRs + 5 arms + 2 humanoids), their compute hardware, and whether you need real-time autonomous control or high-level task allocation, I can propose a concrete architecture and model choices.
Controlling a heterogeneous fleet of different robots (such as a mix of wheeled mobile robots, quadrupedal walkers, robotic arms, and aerial drones) requires a multi-layered AI approach rather than a single monolithic model.[[1]](https://resources.nvidia.com/en-us-public-sector-enterprise-page/gtc25-s71244) Because…
Controlling a heterogeneous fleet of different robots (such as a mix of wheeled mobile robots, quadrupedal walkers, robotic arms, and aerial drones) requires a multi-layered AI approach rather than a single monolithic model.
Because different robot bodies have completely unique actuation spaces, kinematics, and local sensing constraints, the industry relies on a two-tier architecture : a high-level Multi-Agent Foundation Model for fleet coordination and task allocation, coupled with low-level Vision-Language-Action (VLA) or task-specific models running on individual robot form-factors.
The leading frameworks, architectures, and models used for this problem include:
If you are building a control stack today, the industry standard is to use an orchestration layer powered by graph neural networks or multi-agent transformers (similar to DeepFleet 's approach) to handle routing, scheduling, and conflict resolution, which then passes generalized action targets down to localized embodied AI/VLA models running on the individual heterogeneous robots.
To help narrow down the right architectural choice, tell me:

Controlling a heterogeneous fleet of different robots (AGVs, robotic arms, mobile manipulators, and humanoids) isn't handled by a single "all-knowing" neural network running every actuator. Instead, the industry relies on a **hierarchical architecture**: a **Multi-Agent Foundation Model** at the high-level…
Controlling a heterogeneous fleet of different robots (AGVs, robotic arms, mobile manipulators, and humanoids) isn't handled by a single "all-knowing" neural network running every actuator. Instead, the industry relies on a hierarchical architecture: a Multi-Agent Foundation Model at the high-level orchestration layer paired with Vision-Language-Action (VLA) models at the individual robot level.
The top options and approaches for multi-robot fleet control break down as follows:
To give you the most precise recommendation, tell me:
If by **“controlling a fleet of different robots”** you mean a heterogeneous fleet—e.g. wheeled AMRs, robotic arms, drones, humanoids, and custom machines—the best answer in 2026 is **not one model doing everything**. I’d build a hierarchical system. ### My top choice: Gemini Robotics 2 + Gemini Robotics ER 2 Google…
If by “controlling a fleet of different robots” you mean a heterogeneous fleet—e.g. wheeled AMRs, robotic arms, drones, humanoids, and custom machines—the best answer in 2026 is not one model doing everything. I’d build a hierarchical system.
Google DeepMind’s Gemini Robotics 2 is currently the strongest fit I’d investigate first for heterogeneous physical agents.
So I'd architect it roughly like:
                 HUMAN / MISSION
                       │
                       ▼
              Gemini Robotics ER 2
             Fleet-level reasoning
                       │
          ┌────────────┼────────────┐
          ▼            ▼            ▼
       Robot A      Robot B      Robot C
          │            │            │
     VLA / API     VLA / API     VLA / API
          │            │            │
       ┌──┴──┐       ┌─┴───┐       └───┐
       Arm   Base     Drone  Humanoid   ...
The crucial distinction is that ER 2 shouldn't directly be your motor controller. Let it decide what should happen and which robot should do it, while specialized controllers/VLAs handle the millisecond-level details.
| Model/platform | Best for |
|---|---|
| Gemini Robotics 2 / ER 2 | ⭐ Best overall for heterogeneous fleets + reasoning + collaboration |
| NVIDIA Isaac GR00T | ⭐ Best if you're building around NVIDIA hardware/Isaac and want an open robotics stack |
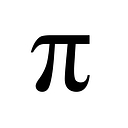
| Physical Intelligence π0 | ⭐ Excellent general-purpose low-level robot policy, particularly manipulation |
| Traditional ROS 2 + specialized models | ⭐ Best for maximum determinism/control in production |
NVIDIA Isaac GR00T is particularly compelling if you're building the infrastructure yourself. It combines a robot foundation model with data pipelines, simulation, middleware, CUDA acceleration, and Jetson deployment rather than being merely an AI model.
π0 from Physical Intelligence is also very interesting: it was trained across multiple robot platforms and is explicitly designed as a generalist vision-language-action policy.
For a serious fleet, I'd use:
ER 2 → fleet orchestration → robot-specific VLA/controller → ROS 2 → safety controller
rather than trying to have a giant LLM directly drive every actuator.
That gives you a separation between:
If you tell me what kinds of robots are in your fleet (e.g. AGVs + arms + drones, humanoids, construction robots, etc.), I can recommend a much more specific architecture—including which model should run where, hardware requirements, ROS 2 design, communication protocol, and how I'd coordinate 10/100/1,000 robots.
| Model/platform | Best for |
|---|---|
| Gemini Robotics 2 / ER 2 | ⭐ Best overall for heterogeneous fleets + reasoning + collaboration |
| NVIDIA Isaac GR00T | ⭐ Best if you're building around NVIDIA hardware/Isaac and want an open robotics stack |
| Physical Intelligence π0 | ⭐ Excellent general-purpose low-level robot policy, particularly manipulation |
| Traditional ROS 2 + specialized models | ⭐ Best for maximum determinism/control in production |
NVIDIA Isaac GR00T is particularly compelling if you're building the infrastructure yourself. It combines a robot foundation model with data pipelines, simulation, middleware, CUDA acceleration, and Jetson deployment rather than being merely an AI model.
π0 from Physical Intelligence is also very interesting: it was trained across multiple robot platforms and is explicitly designed as a generalist vision-language-action policy.
For a serious fleet, I'd use:
ER 2 → fleet orchestration → robot-specific VLA/controller → ROS 2 → safety controller
If by “controlling a fleet” you mean **one AI system coordinating different robot types**—e.g. mobile bases, arms, humanoids, drones, etc.—I would **not use a single end-to-end model as the fleet controller**. ### My pick: NVIDIA Isaac GR00T + a fleet-level reasoning layer For a heterogeneous fleet today, **NVIDIA…
If by “controlling a fleet” you mean one AI system coordinating different robot types—e.g. mobile bases, arms, humanoids, drones, etc.—I would not use a single end-to-end model as the fleet controller.
For a heterogeneous fleet today, NVIDIA Isaac GR00T is probably the strongest starting point if you want something you can actually customize and deploy. GR00T is explicitly designed for cross-embodiment robot skills, accepts vision/language/proprioception, and can be adapted to new hardware with additional demonstrations. GR00T N1.7 is also commercially licensable under Apache 2.0.
I'd structure the system roughly like this:
                 Fleet AI / Mission Planner
                         │
          ┌──────────────┼──────────────┐
          ▼              ▼              ▼
       Robot A        Robot B        Robot C
      humanoid       mobile arm       drone
          │              │              │
      GR00T/VLA      GR00T/VLA      specialized
          │              │              │
       low-level controllers / ROS 2
The important distinction is that the fleet AI decides what should happen, while each robot's VLA/controller decides how that particular body performs it.
Google DeepMind Gemini Robotics 2 is arguably the more impressive choice if your priority is general reasoning and heterogeneous robot interaction rather than openness. Google explicitly describes Gemini Robotics 2 as supporting different robot embodiments and multi-robot collaboration, with a separate Gemini Robotics ER 2 model handling embodied reasoning and multi-step planning.
So my ranking would be:
| Goal | Best choice |
|---|---|
| Build/customize a heterogeneous fleet | GR00T |
| Best general-purpose embodied reasoning | Gemini Robotics 2 |
| Maximum control over weights/data/infrastructure | GR00T / open VLA ecosystem |
| Fleet-level planning | A frontier multimodal reasoning model + robotics-specific models |
| Hard real-time motor control | Dedicated robot controllers, not an LLM |
One important caveat: today's robot foundation models are not yet a solved universal fleet brain. Stanford's 2026 AI Index notes that VLAs remain largely at the research stage and that the gap between controlled demonstrations and reliable real-world operation is still substantial.
If you're actually building a heterogeneous robot fleet, tell me what types of robots you have (e.g. 10 AMRs + 5 arms + 2 humanoids) and what the fleet needs to accomplish. I can recommend a concrete architecture—including model, ROS 2, simulation, networking, fleet scheduler, inference hardware, and how the robots should communicate with each other.
When controlling a **heterogeneous fleet of different robots** (e.g., a mix of AMRs, robotic arms, quadrupeds, and humanoids from different vendors), there is no single "all-in-one" AI model that directly drives every motor and joint across completely different form factors. Instead, the industry relies on a…
When controlling a heterogeneous fleet of different robots (e.g., a mix of AMRs, robotic arms, quadrupeds, and humanoids from different vendors), there is no single "all-in-one" AI model that directly drives every motor and joint across completely different form factors. Instead, the industry relies on a hierarchical architecture combining high-level Vision-Language-Action (VLA) or Large Language Models (LLMs) for fleet orchestration, coupled with standardized middleware and hardware-specific foundation models.
The leading ecosystems and approaches for managing mixed robot fleets break down as follows:
To help narrow down the ideal stack, tell me:
When controlling a **heterogeneous fleet of different robots** (e.g., mobile AGVs, robotic arms, quadrupeds, and humanoids), there is no single "all-in-one" AI model that directly twitches every motor across entirely different physical bodies. Instead, the industry relies on a **hierarchical hybrid architecture**…
When controlling a heterogeneous fleet of different robots (e.g., mobile AGVs, robotic arms, quadrupeds, and humanoids), there is no single "all-in-one" AI model that directly twitches every motor across entirely different physical bodies. Instead, the industry relies on a hierarchical hybrid architecture where different layers of AI collaborate.
The most effective approach divides control into High-Level Orchestration (the Fleet Brain) and Low-Level Execution (the Robot Body).
Phase 1: High-Level Orchestration (Fleet Brain)
To manage task allocation, natural language commands, traffic routing, and cross-platform cooperation, Multimodal Large Language Models (MLLMs) and Vision-Language-Action (VLA) frameworks serve as the top-level coordinators.
Phase 2: Mid-Level Coordination & Traffic (Multi-Agent Navigation)
Different robots moving through the same space create exponential congestion. Classical fleet management algorithms fail when robot densities and types vary wildly.
Phase 3: Low-Level Control (The Robot Body)
An LLM cannot natively handle 100Hz joint torques. Every individual robot in the fleet must still run its own localized edge intelligence.
Summary Architecture Recommendation
If you are designing a heterogeneous fleet control system today, use a three-tier stack:
If you'd like to narrow this down, tell me:
I can help you map out a more specific software stack or integration framework.
If you mean **one AI system that can coordinate a heterogeneous fleet**—e.g. mobile robots, robotic arms, humanoids, drones, AGVs/AMRs, etc.—my current pick would be **Google DeepMind’s Gemini Robotics 2 family**, but **not as the sole controller**.…
If you mean one AI system that can coordinate a heterogeneous fleet—e.g. mobile robots, robotic arms, humanoids, drones, AGVs/AMRs, etc.—my current pick would be Google DeepMind’s Gemini Robotics 2 family, but not as the sole controller.
Best overall architecture:
                Fleet / Mission Manager
                         │
                Gemini Robotics ER 2
              (reasoning + planning)
                         │
          ┌──────────────┼──────────────┐
          ▼              ▼              ▼
       Robot A        Robot B        Robot C
       VLA policy     VLA policy     VLA policy
          │              │              │
       ROS 2 /       ROS 2 /       ROS 2 /
       controller    controller    controller
The important distinction is that fleet coordination and low-level robot control are different problems.
Google specifically describes Robotics 2 as supporting different robot embodiments and multi-robot collaboration, including robots communicating and dividing work.
The killer feature isn't simply "best vision model." It's cross-embodiment generalization.
Google reports that its robotics models can transfer learned behaviors between substantially different platforms. Earlier Gemini Robotics 1.5, for example, demonstrated transfer among ALOHA 2, Franka and Apptronik's Apollo humanoid.
That's unusually relevant if your fleet looks something like:
50 AMRs + 10 arms + 5 humanoids + inspection drones rather than 50 identical robots.
If your priority is owning the stack and running it yourself, I'd look very seriously at NVIDIA's robotics ecosystem, particularly GR00T + Cosmos + Isaac.
NVIDIA's GR00T N1.6 is an open foundation VLA model aimed at generalist humanoid robots, while the broader NVIDIA stack provides simulation, synthetic data, perception/reasoning and deployment infrastructure.
So I'd roughly rank the approaches:
| Goal | My pick |
|---|---|
| Best heterogeneous-robot intelligence | Gemini Robotics 2 |
| High-level fleet reasoning/planning | Gemini Robotics ER 2 |
| On-device robotic intelligence | Gemini Robotics On-Device 2 |
| Open/self-hosted ecosystem | NVIDIA GR00T + Cosmos + Isaac |
| Hard real-time control | Traditional robot controllers, not an LLM |
| Fleet scheduling/optimization | Dedicated planner/optimizer + AI reasoning layer |
One important caveat: I would not let a foundation model directly command motors or safety-critical actuators. Put it above deterministic navigation, motion planning, collision avoidance and safety systems. The AI should decide what should happen; conventional robotics software should constrain and execute how it physically happens.
If you tell me what kinds of robots are in your fleet (e.g. drones, humanoids, arms, AMRs), how many, and whether they need to operate autonomously/offline, I can give you a concrete architecture and recommend the specific models/hardware I'd use.
If by **“controlling a fleet of different robots”** you mean something like *10–1,000 robots of different embodiments—AMRs, arms, quadrupeds, humanoids, drones—with one AI system coordinating what they do*, I would **not** pick a single end-to-end model and have it directly drive every motor. ### My pick in 2026:…
If by “controlling a fleet of different robots” you mean something like 10–1,000 robots of different embodiments—AMRs, arms, quadrupeds, humanoids, drones—with one AI system coordinating what they do, I would not pick a single end-to-end model and have it directly drive every motor.
For the fleet-level intelligence, Google DeepMind’s Gemini Robotics ER 2 is probably the most interesting choice right now. Google explicitly designed it as a high-level embodied-reasoning model that can do spatial reasoning, multi-step planning, progress monitoring, tool use, and multi-robot orchestration, while handing actual motor execution to lower-level VLA/control policies.
The architecture I'd use is roughly:
                    ┌──────────────────────────┐
                    │   Fleet Intelligence      │
                    │   Gemini Robotics ER 2    │
                    │                          │
                    │ • Understand mission      │
                    │ • Decompose tasks         │
                    │ • Allocate robots         │
                    │ • Monitor progress        │
                    │ • Re-plan / recover       │
                    └────────────┬─────────────┘
                                 │
                     ROS 2 / fleet API / tools
                                 │
              ┌──────────────────┼──────────────────┐
              ▼                  ▼                  ▼
        ┌──────────┐       ┌──────────┐       ┌──────────┐
        │   AMRs   │       │   Arms   │       │ Humanoids│
        │ Nav policy│       │ VLA      │       │ VLA      │
        └──────────┘       └──────────┘       └──────────┘
              │                  │                  │
        local planner       motion control     whole-body control
              │                  │                  │
              └────────────── safety layer ────────┘
That's much more scalable than asking one giant model to output joint commands for every robot.
If your priority is actually deploying this commercially, rather than choosing the theoretically smartest model, I'd seriously consider NVIDIA's Isaac ecosystem.
NVIDIA's current stack combines Isaac ROS/ROS 2, Isaac Sim, Isaac Lab, foundation models such as GR00T, accelerated perception and motion planning, and on-robot inference. Importantly, NVIDIA explicitly supports autonomous mobile robots, arms, manipulators and humanoids rather than focusing solely on one embodiment.
Their GR00T N1.7 is particularly interesting if many of your robots are manipulators/humanoids: it's an open, commercially licensable VLA designed for cross-embodiment generalization and can be fine-tuned to particular robots and tasks.
| Approach | Fleet orchestration | Cross-robot control | Deployment | My take |
|---|---|---|---|---|
| Gemini Robotics ER 2 | ⭐⭐⭐⭐⭐ | ⭐⭐⭐⭐⭐ | ⭐⭐⭐ | Best fleet brain |
| NVIDIA Isaac + GR00T | ⭐⭐⭐⭐ | ⭐⭐⭐⭐⭐ | ⭐⭐⭐⭐⭐ | Best overall engineering stack |
| Gemini Robotics 2 VLA | ⭐⭐⭐ | ⭐⭐⭐⭐⭐ | ⭐⭐⭐⭐ | Excellent robot-level policy |
| GR00T N1.7 | ⭐⭐⭐ | ⭐⭐⭐⭐⭐ | ⭐⭐⭐⭐⭐ | Excellent open/customizable option |
| General-purpose LLM alone | ⭐⭐⭐⭐ | ⭐ | ⭐⭐⭐ | Don't use it for direct control |
Google's newer Gemini Robotics 2 is also notable because it is explicitly aimed at whole-body control, dexterity, teamwork, and adaptation across different robot bodies; its on-device version is intended to run locally on robots.
The best “robot fleet model” isn't actually one model.
I'd build a hierarchical robotics AI system:
That separation is important because an LLM/VLM is good at deciding “send robot 17 to inspect aisle 4”, whereas a 1-kHz controller is better at deciding “what torque should joint 3 receive right now?”
If you tell me what kinds of robots are in your fleet (e.g. Boston Dynamics, Unitree, drones, AMRs, robot arms), how many, and whether you want cloud or on-device control, I can recommend a concrete architecture—including the model, ROS 2 setup, GPUs, APIs, and how I'd train/fine-tune it.
That's much more scalable than asking one giant model to output joint commands for every robot.
If your priority is actually deploying this commercially, rather than choosing the theoretically smartest model, I'd seriously consider NVIDIA's Isaac ecosystem.
NVIDIA's current stack combines Isaac ROS/ROS 2, Isaac Sim, Isaac Lab, foundation models such as GR00T, accelerated perception and motion planning, and on-robot inference. Importantly, NVIDIA explicitly supports autonomous mobile robots, arms, manipulators and humanoids rather than focusing solely on one embodiment.
Their GR00T N1.7 is particularly interesting if many of your robots are manipulators/humanoids: it's an open, commercially licensable VLA designed for cross-embodiment generalization and can be fine-tuned to particular robots and tasks.
| Approach | Fleet orchestration | Cross-robot control | Deployment | My take |
|---|---|---|---|---|
| Gemini Robotics ER 2 | ⭐⭐⭐⭐⭐ | ⭐⭐⭐⭐⭐ | ⭐⭐⭐ | Best fleet brain |
| NVIDIA Isaac + GR00T | ⭐⭐⭐⭐ | ⭐⭐⭐⭐⭐ | ⭐⭐⭐⭐⭐ | Best overall engineering stack |
| Gemini Robotics 2 VLA | ⭐⭐⭐ | ⭐⭐⭐⭐⭐ | ⭐⭐⭐⭐ | Excellent robot-level policy |
| GR00T N1.7 | ⭐⭐⭐ | ⭐⭐⭐⭐⭐ | ⭐⭐⭐⭐⭐ | Excellent open/customizable option |
| General-purpose LLM alone | ⭐⭐⭐⭐ | ⭐ | ⭐⭐⭐ | Don't use it for direct control |
Google's newer Gemini Robotics 2 is also notable because it is explicitly aimed at whole-body control, dexterity, teamwork, and adaptation across different robot bodies; its on-device version is intended to run locally on robots.
The best “robot fleet model” isn't actually one model.
I'd build a hierarchical robotics AI system:
When it comes to controlling a **heterogeneous fleet** (a mix of different robots like drones, wheeled AGVs, robotic arms, and humanoids), there is no single "drop-in" neural network that directly handles low-level motor controls for every distinct machine shape out of the box. Instead, the industry relies on a…
When it comes to controlling a heterogeneous fleet (a mix of different robots like drones, wheeled AGVs, robotic arms, and humanoids), there is no single "drop-in" neural network that directly handles low-level motor controls for every distinct machine shape out of the box. Instead, the industry relies on a hierarchical architecture combining high-level Vision-Language-Action (VLA) foundation models for reasoning with specialized multiemembodiment frameworks for execution.
The top-performing frameworks, models, and architectures used to orchestrate diverse robot fleets include:
At the fleet management layer, high-level models act as the "dispatcher" or "brain" that translates natural language commands or overall mission goals into sub-tasks for specific robots.
RT-1-X, RT-2-X): Built on the Open X-Embodiment dataset, RT-X was trained across 22 different robot types . It is one of the premier cross-embodiment generalist models, meaning a single high-capacity model can transfer learned manipulation and movement skills from one robot morphology to an entirely different physical form.For direct sensor-to-action control across diverse hardware, generalist action models map diverse inputs to distinct robot kinematics:
No AI model runs a multi-vendor fleet in isolation; it requires a unifying operating system.
Summary Recommendation
If you want to narrow this down, tell me:
π0